To bring self-driving cars to the majority of the world, the autonomous vehicle industry must adapt to the informal traffic dynamics of emerging markets.
Since autonomous vehicles (AVs) first started being tested on California’s roads in the late 2000s, the industry has directed enormous resources towards proving that driverless technology works in highly structured, well-mapped environments built for predictability.
And it has largely succeeded: Waymo operates across multiple US cities, autonomous trucks are already hauling freight on American highways, and the technology is currently preparing for a wider European rollout. It’s now clear that AVs can navigate the world’s most predictable roads. The issue, however, is that predictable roads are not where most of the world drives.
The harder, more consequential task is making this technology work in emerging and frontier markets, where infrastructure is inconsistent and driving behaviour is less predictable, often negotiated peer-to-peer rather than prescribed by law.
If the industry can solve this challenge, it will succeed in bringing AVs to the majority of the world’s population. At the same time, it’ll likely also make autonomous driving technology better for all environments across the globe.
The limits of current AV economics
The first problem is surprisingly not technology, but the cost and economics. A single AV, including the vehicle, sensor suite and onboard processing platform, costs upwards of $100,000. That’s viable in wealthy markets, but not where most of the world’s population lives.
For autonomous mobility to work at scale in emerging geographies, that cost needs to fall closer to $10,000 – a target the industry has yet to achieve.
As for the technology itself, technical intelligence trained on one geographic and cultural environment cannot simply transfer to another that’s vastly different. Most global AV models have been trained using driving footage and traffic data from the US and Europe, creating a gap between the behavioural logic these models learned and the logic that governs roads across much of Asia, Africa and Latin America.
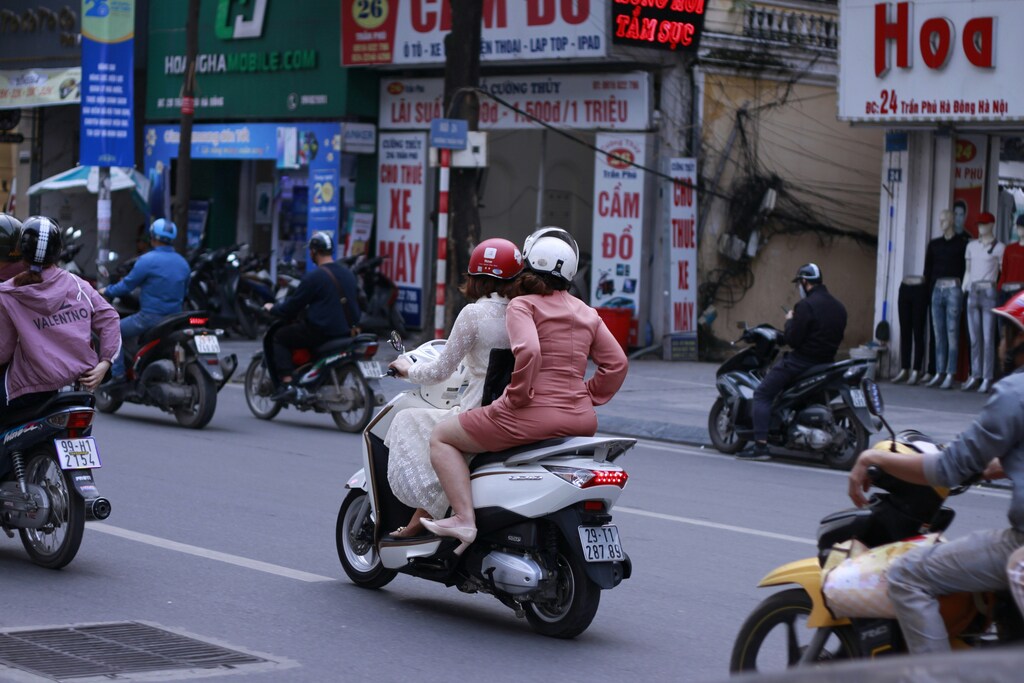
Another issue is that driving safely is as much a social skill as a technical one in many developing countries. At a busy, signal-less intersection in Hanoi, for example, hundreds of motorcycles may pass through in a minute, despite no traffic lights or clear rules indicating who should move when. What appears to outside observers as chaos is, to the riders themselves, a continuous stream of negotiation, with right of way set not by formalized traffic laws, but rather by subtle cues like eye contact, a held glance, or a slight shift in speed.
For AVs trained on Western, formulaic roads, this same intersection reads as pure unpredictability – AVs could either freeze, or, worse, misinterpret the situation and initiate a dangerous manoeuvre.
To succeed globally, the industry must adapt to environments where informal driving rules and unpredictability are the norm rather than the exception.
Urban growth is moving to frontier markets
Established thinking says emerging markets are complex, infrastructure is limited, and the economics are harder. This adage in fact misses the bigger picture.
Yet the AV industry’s priorities misread where global economic growth is heading. Emerging markets will account for most of global urban growth. Over half of the projected 986 million increase in global city dwellers by 2050 will be concentrated in just seven countries: India, Nigeria, Pakistan, the DRC, Egypt, Bangladesh and Ethiopia. The cities AV technology currently cannot reach are also the cities growing fastest.
Rethinking AV data for unstructured roads
Closing that gap means rethinking the AV development pipeline from the ground up. Unfortunately, there is no easy fix like rolling out better sensors.
This starts with “chain of causation” datasets. AVs need to understand not just the "what" of what other road users are doing, but also the "why". In other words, they must understand the trigger behind the response. That requires a new annotation layer that links cause to behaviour, verified by local drivers who actually know those streets.
It also requires access to live operational intelligence, or live HD maps. Static maps can’t capture what vehicles need to know, including real-time updates on road closures, weather changes, and local behavioural patterns that drivers learn on the ground.
Just as important is the infrastructure to generate that intelligence at scale: outfitting high-mileage fleets with multi-camera systems, GPS and inertial measurement units. Critically, these sensors need to be paired with on-device edge AI that pre-flags the edge cases that actually matter – filtering out hours of routine stop-and-go traffic to save terabytes of cloud storage and blurring faces for privacy.
Finally, there’s localized simulation: testing in closed-loop environments using real local street footage, rather than generic, Western-modelled maps.
Why complex traffic builds better AI
At inDrive, we operate across 1,200+ cities and 48 emerging and frontier markets, where these challenges are our operational reality and shape how we think about where AVs need to go next.
If AVs can safely navigate the chaotic streets of Delhi, Jakarta or Lagos, they will almost certainly handle the world’s most orderly roads. The behavioural complexity in these markets represents the full range of how humans use roads, compressed into higher frequency.
The next decade of autonomy won’t be defined by how well AVs perform in predictable environments, but rather how well they adapt to everywhere else.
Ensuring a just transition for drivers
Solving AV tech in these markets is key, but addressing the social impacts matters just as much. Driving is how millions of people in these markets support their families. Any serious plan for autonomy there must reckon with that directly.
We believe that the goal should not be to replace these drivers, but to give them a stake in this future technology. That means helping drivers become owner-operators of AVs, earning from their fleet assets rather than losing the income their old vehicle provided. It also means treating today’s drivers as the foundation autonomy is built on, rather than the population it displaces.
After all, autonomous mobility that succeeds technically but destroys the livelihoods of those currently providing that mobility will have solved the wrong problem. The industry should not only be judged on where its vehicles can drive, but crucially, on who gets to benefit when they do.